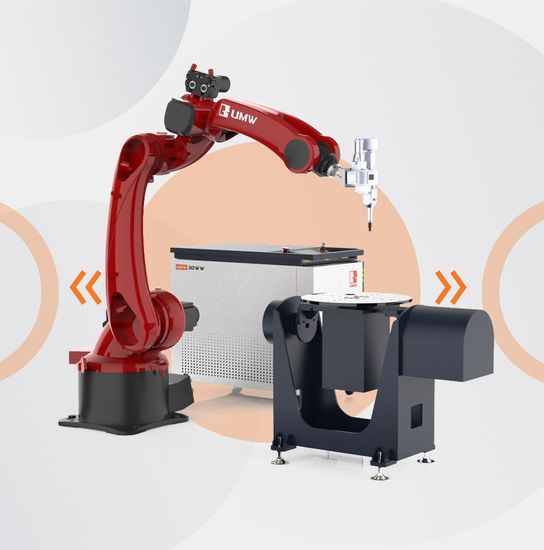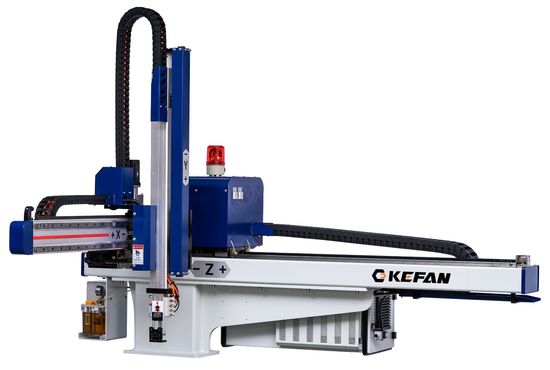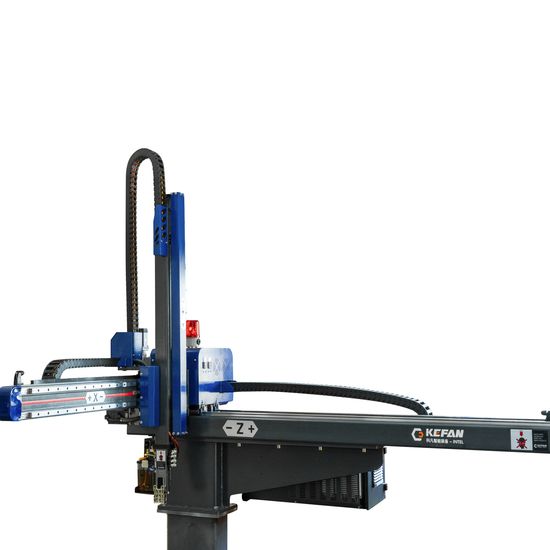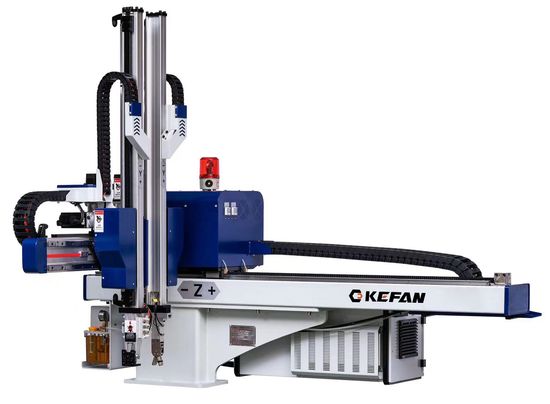


Full-Automatic CNC Matched Robotic Hand for Workshop Loading Unloading Collaborative Manipulator
US$5,000.00-19,000.00
1 Set(MOQ)

CNC-Integrated Robotic Hand for Automatic Material Loading/Unloading Safety-Rated Collaborative Motor
US$10,000.00-20,000.00
1 Set(MOQ)

Collaborative 3-Axis CNC-Integrated Robotic Hand for Factory Unmanned Production Processing
US$5,000.00-20,000.00
1 Set(MOQ)

High-Speed CNC-Integrated Robotic Hand for Increased Productivity ODM Arm Manipulator
US$5,000.00-8,000.00
1 Set(MOQ)

User Friendly CNC-Integrated Robotic Hand & 3 Axis Robot for Metalworking
US$8,000.00-20,000.00
1 Set(MOQ)

CNC-Integrated Robotic Hand for Industrial Metal Machining Loading Unloading Robot
US$5,000.00-200,000.00
1 Set(MOQ)

Reliable CNC Synced Robotic Hand for Auto Pick Place Collaborative Robot
US$9,000.00
1 Set(MOQ)

Industrial Automatic Mechanical Arm CNC-Integrated Robotic Hand for Metal Fabrication Industry
US$4,500.00-20,000.00
1 Set(MOQ)

10kg Payload up-Down Material Taking 3-Axis Robotic Arm & CNC-Integrated Robotic Hand
US$5,000.00-20,000.00
1 Set(MOQ)

Economical CNC-Integrated Robotic Hand for Lathe Automation with CE Safety Certification
US$3,000.00-20,000.00
1 Set(MOQ)

Advanced CNC-Integrated Robotic Hand for Maximize Output 6-Axis Cobot Arm Manipulator
US$5,000.00-20,000.00
1 Set(MOQ)

Professional CNC-Integrated Robotic Hand for Increased Productivity 6-Axis Cobot Arm Manipulator
US$5,000.00-19,000.00
1 Set(MOQ)

Servo Driven Automatic Manipulation Arm & CNC-Integrated Robotic Hand with 10kg Payload
US$5,000.00-8,000.00
1 Set(MOQ)